STM32 Quadcopter
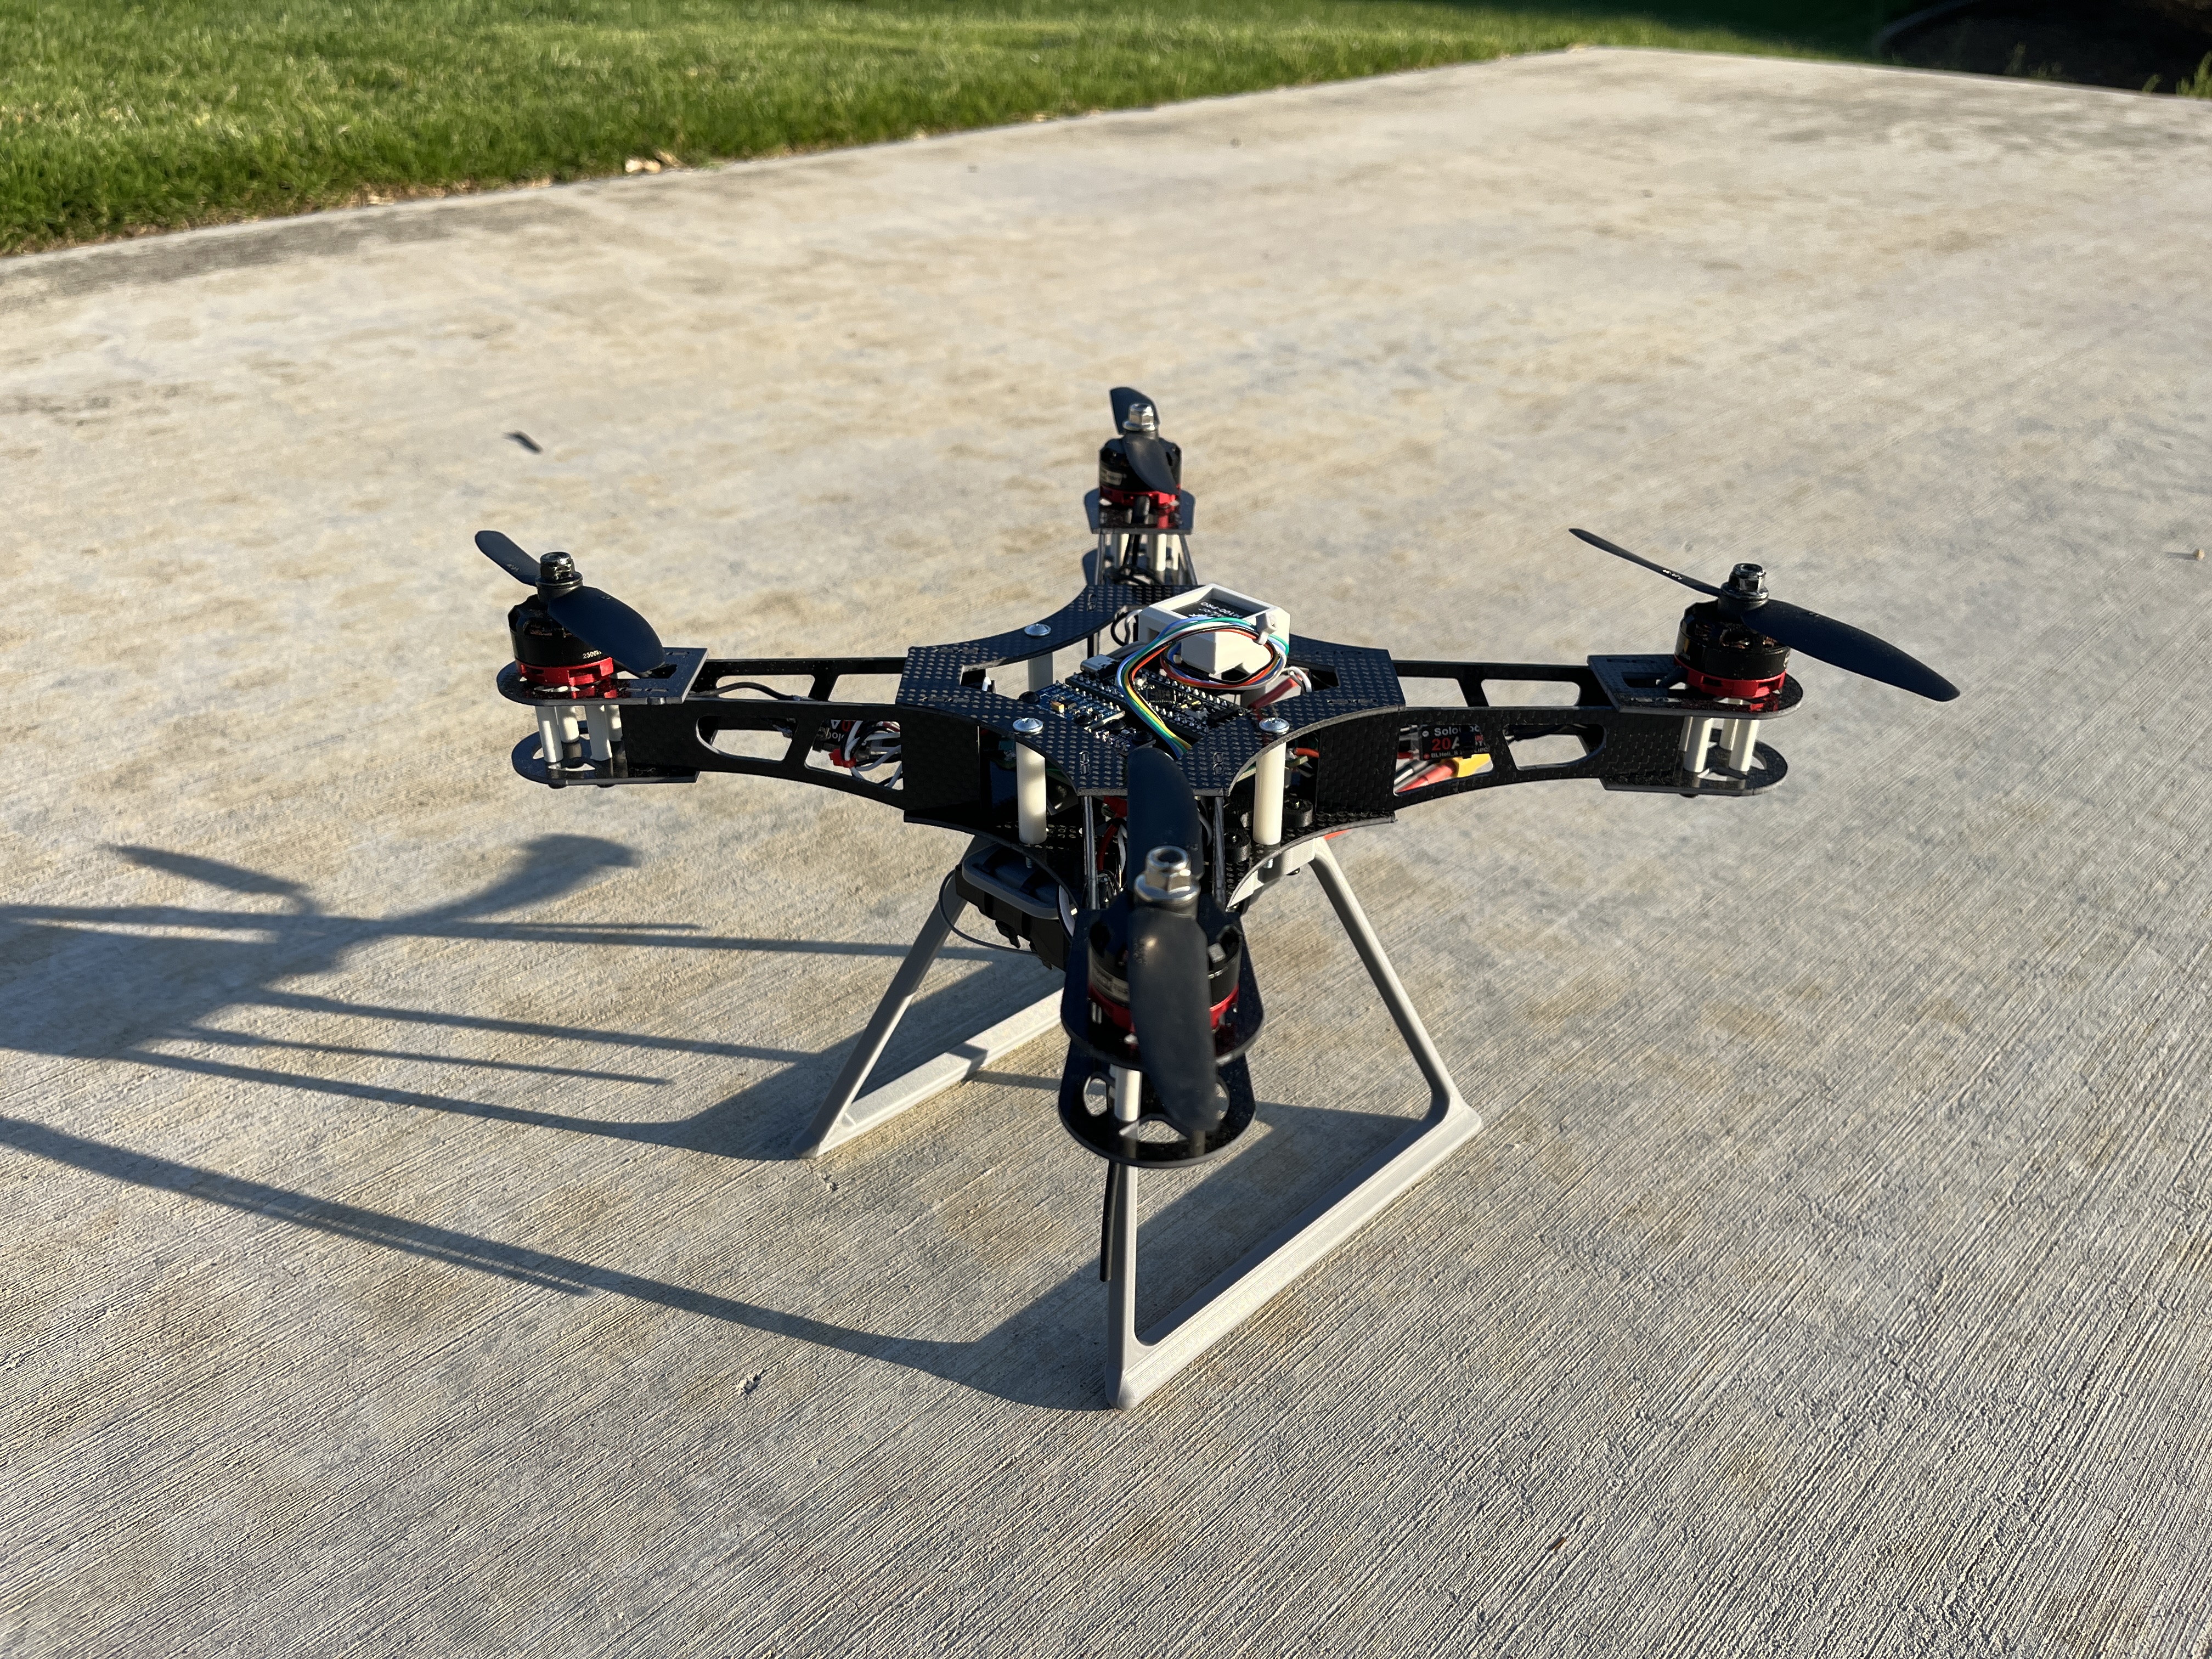
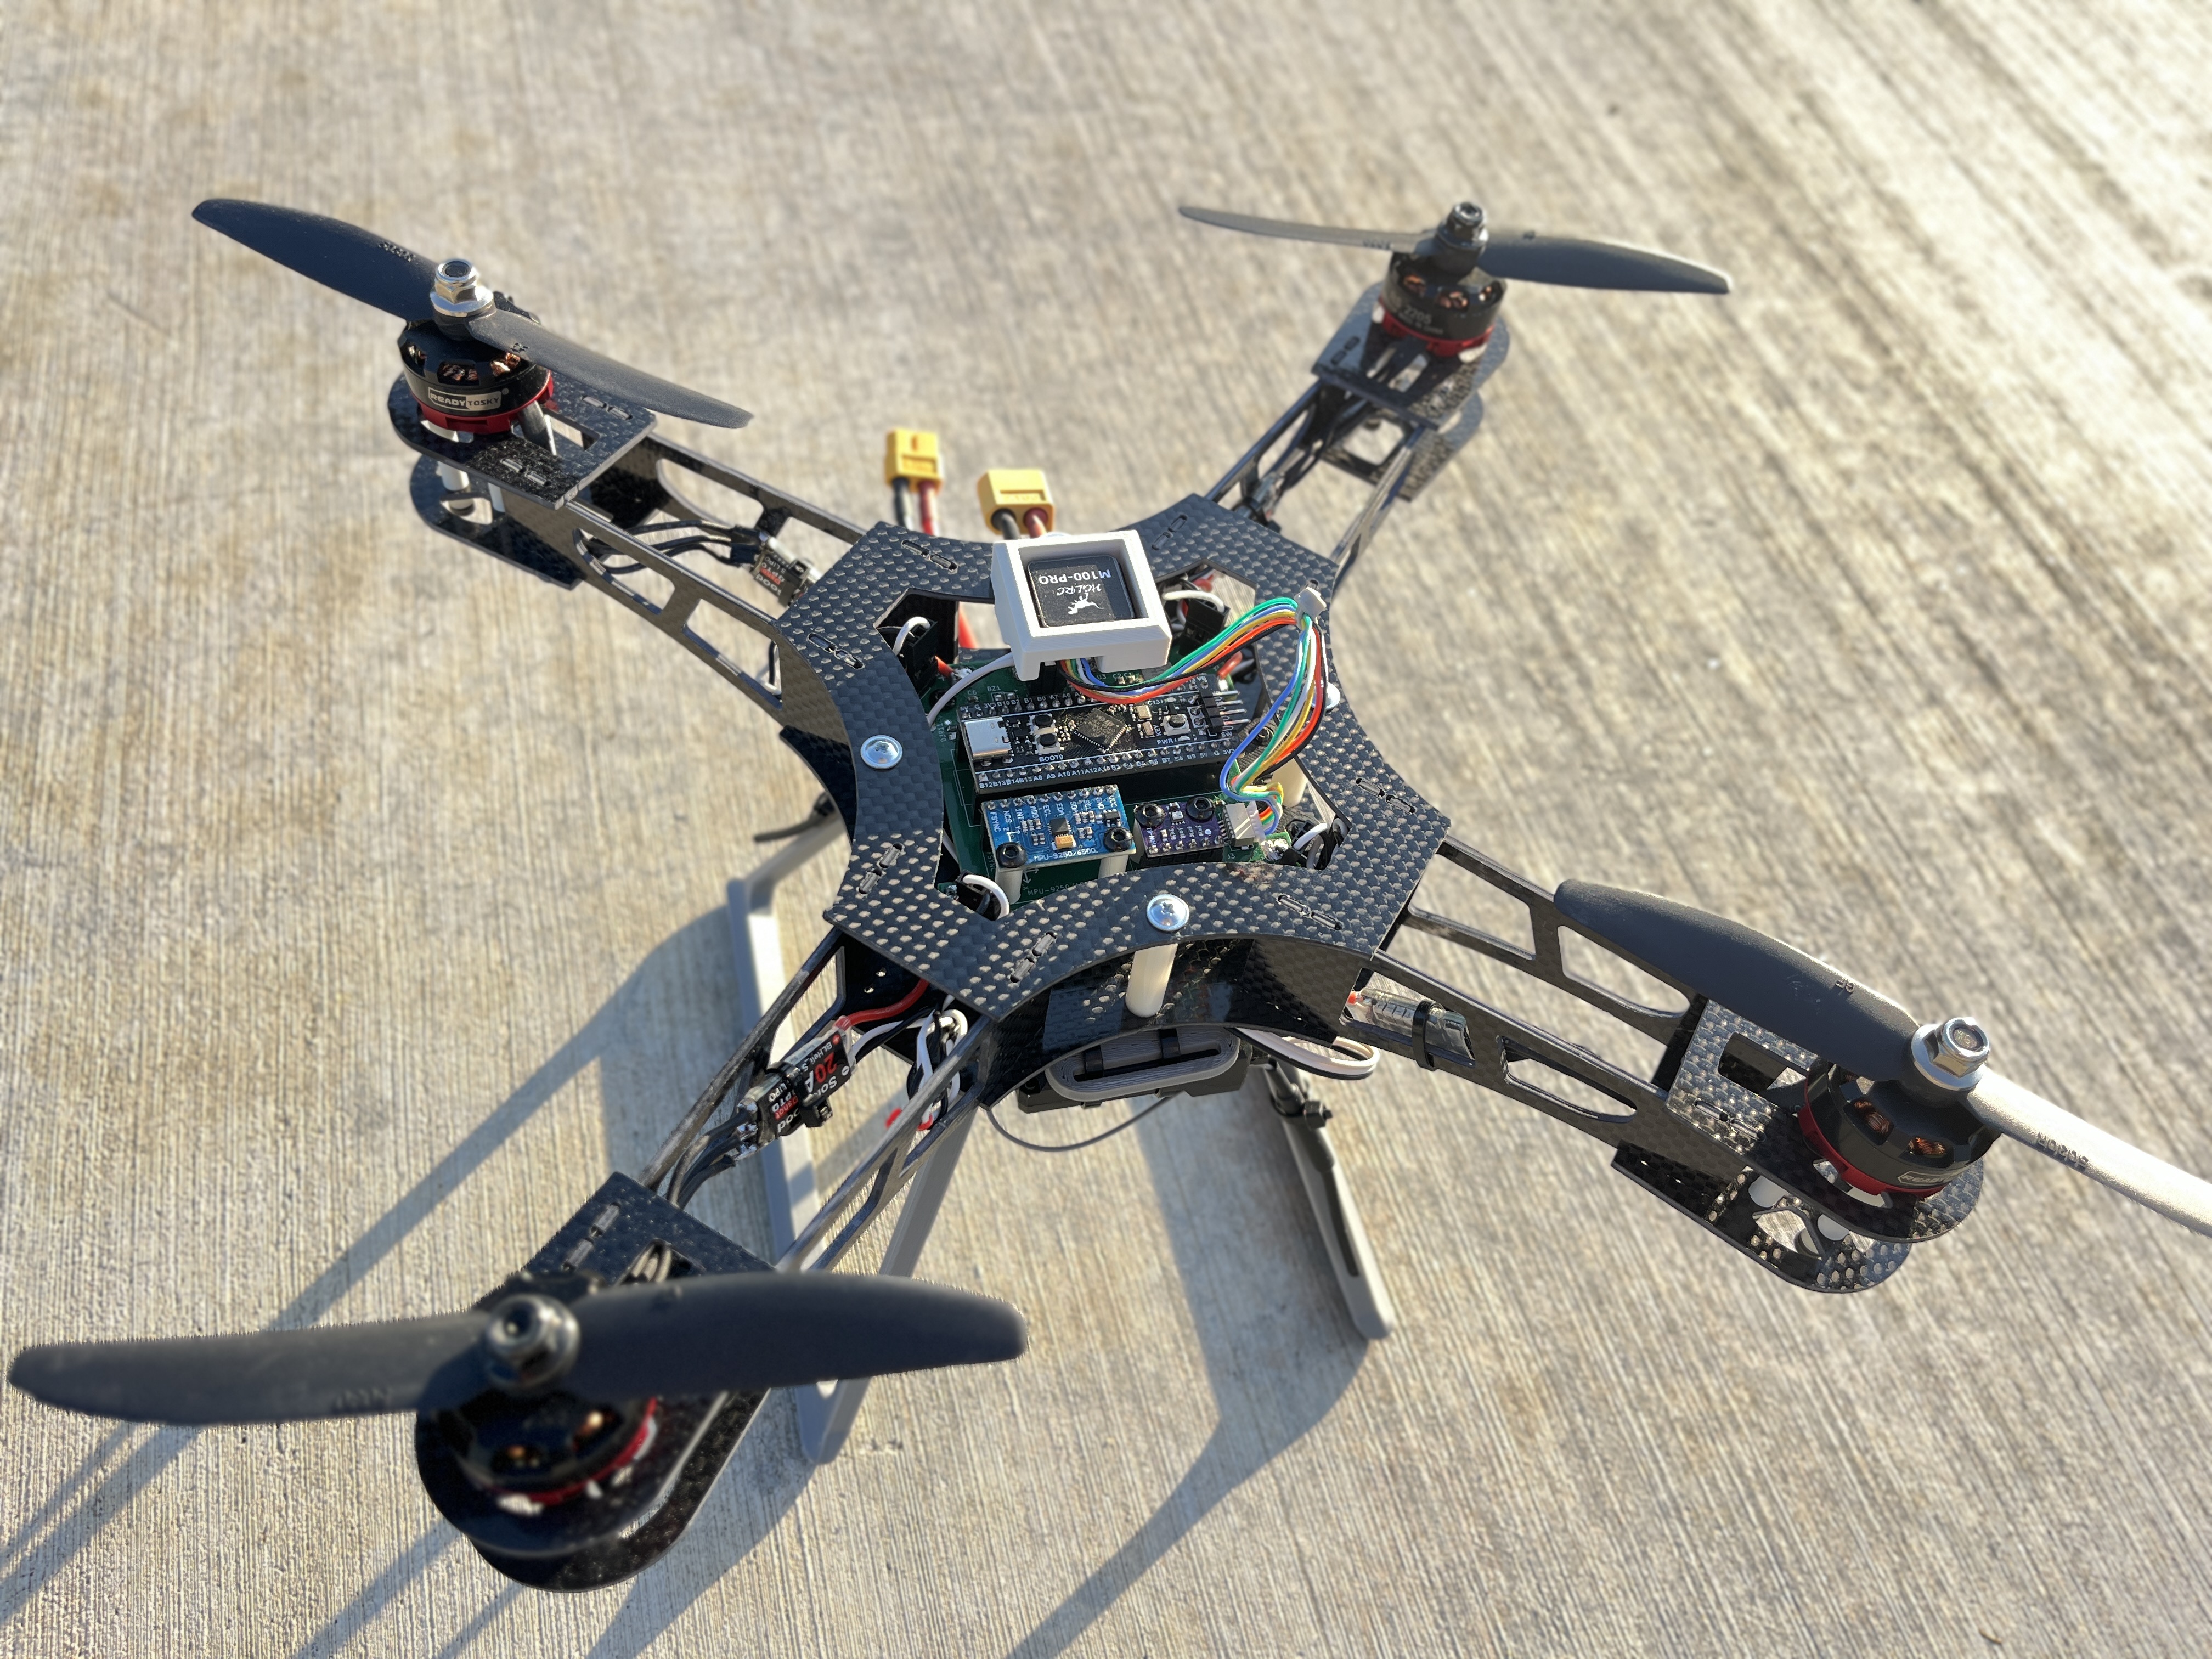
STM32 Quadcopter is a community-built motor control board. I-M-Robotics-Lab publishes the full project on GitHub for anyone to study or build. The project summarises itself as “Quadcopter design based on STM32F411CEU Blackpill flight controller. Compatible with INAV 6.0 firmware.”
The repository has collected 63 stars and been forked 10 times, with the last commit 10 months ago.
What’s in the repository
- Schematic and board source files published by the author
- Full revision history, so you can see how the board changed between versions
Licence and reuse
Released under GPL-3.0, a copyleft license. You are free to fork and modify the design, but anything you distribute that is derived from it has to be published under the same terms — worth checking before it goes into a closed product.
Opening it in ProtoFlow
The repository does not clearly state which EDA tool produced the files — check the repository contents before planning an import.
- 01 Select “Edit in ProtoFlow” for opening options. Download the source and open supported KiCad files in the app. Other EDA formats may need conversion.
- 02 Work in the imported local copy: rename nets, swap parts against live distributor stock, re-route, or strip it back to the sub-circuit you actually need.
- 03 Keep the original licence and credit I-M-Robotics-Lab if you publish or sell what you build from it.
This page indexes a public repository. The design, the files and the copyright belong to I-M-Robotics-Lab; ProtoFlow does not host, mirror or verify them. Details are read from GitHub and refreshed periodically — check the repository for the current state of the project.