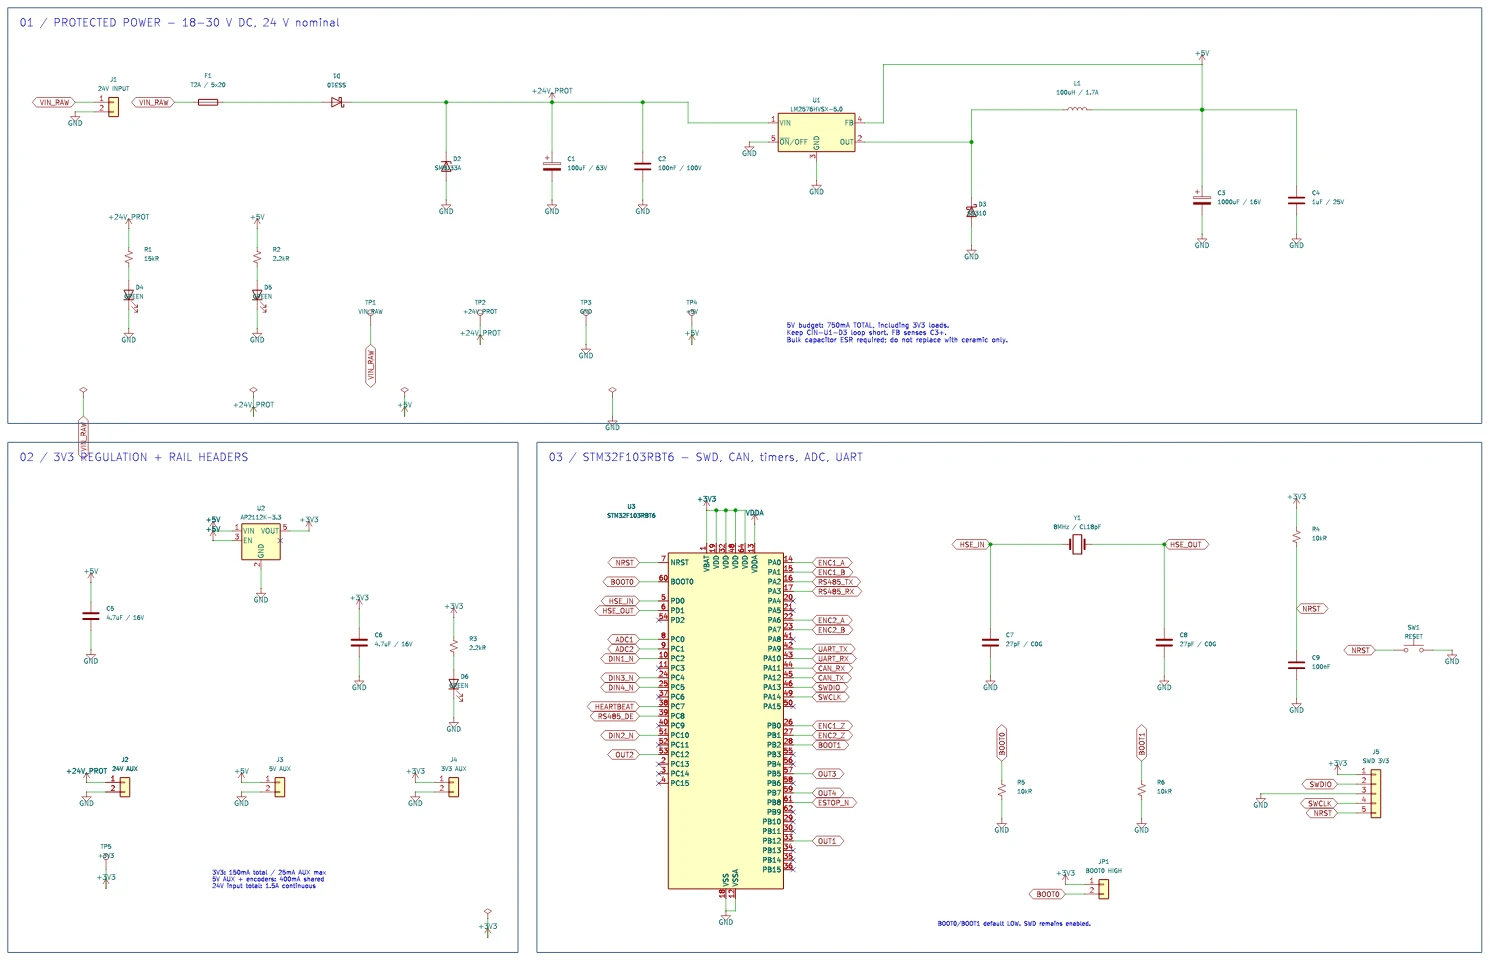
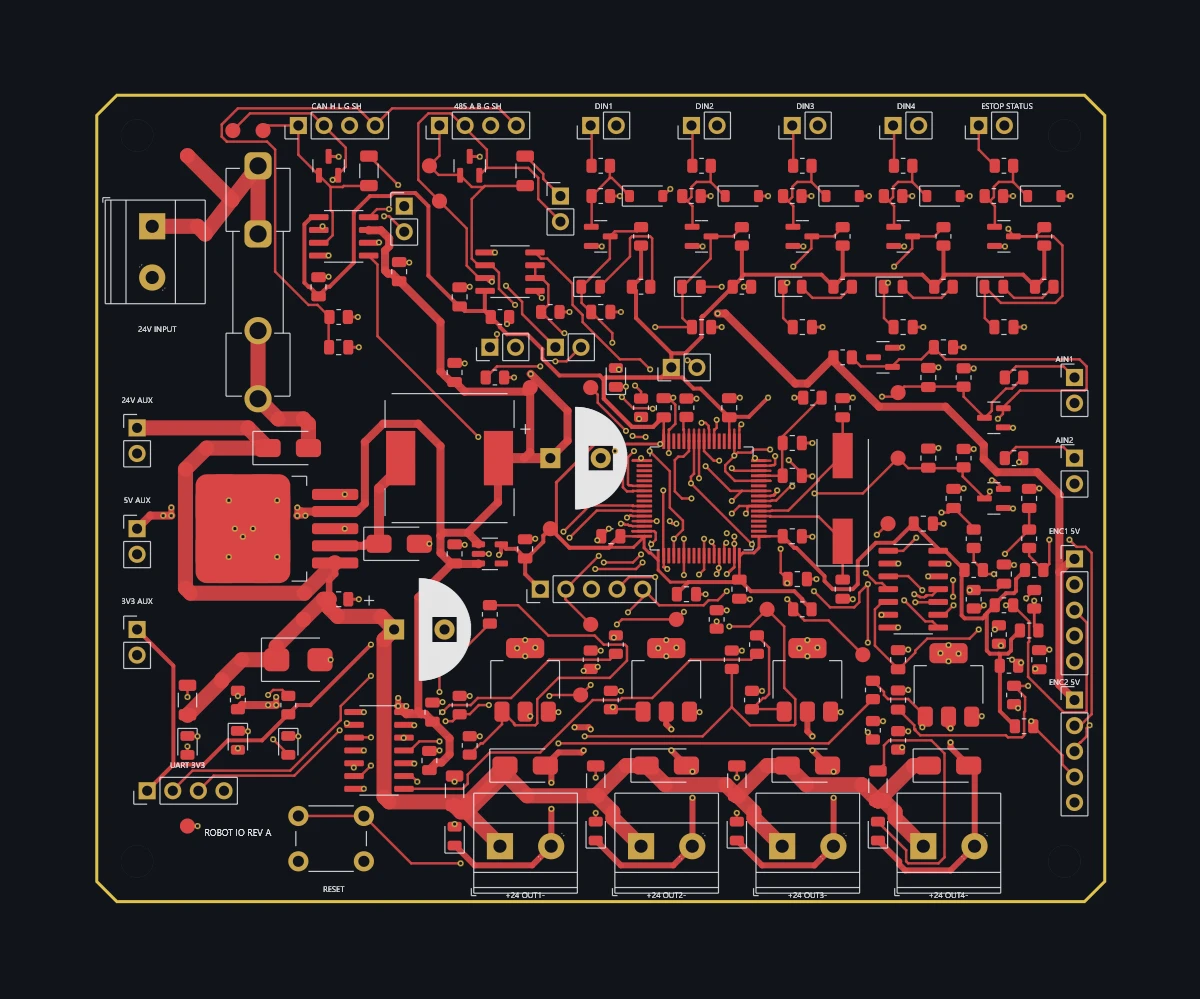
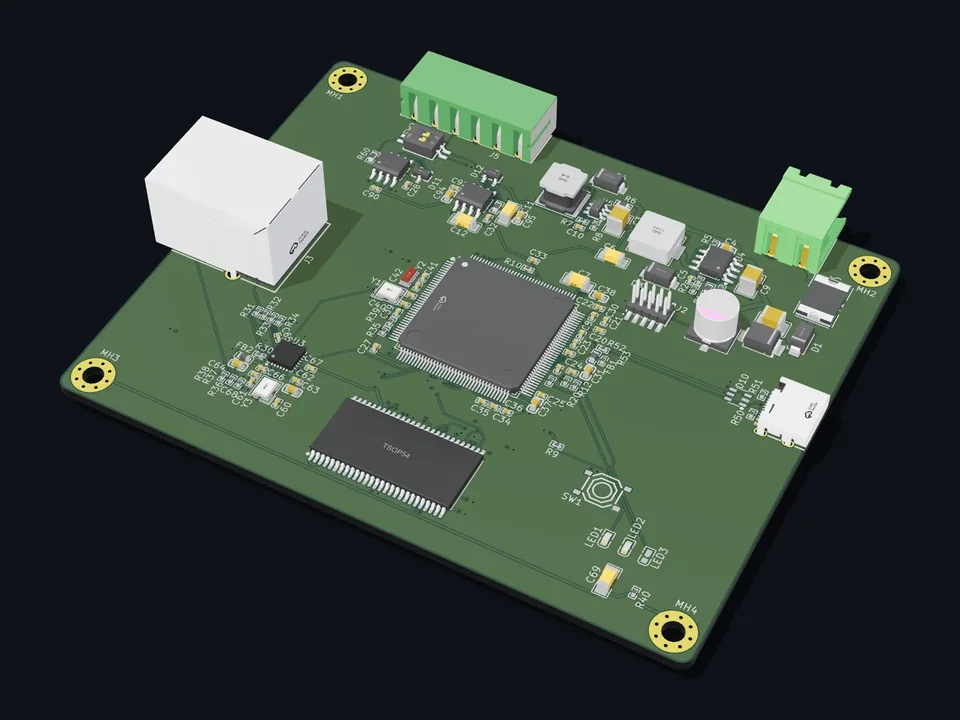
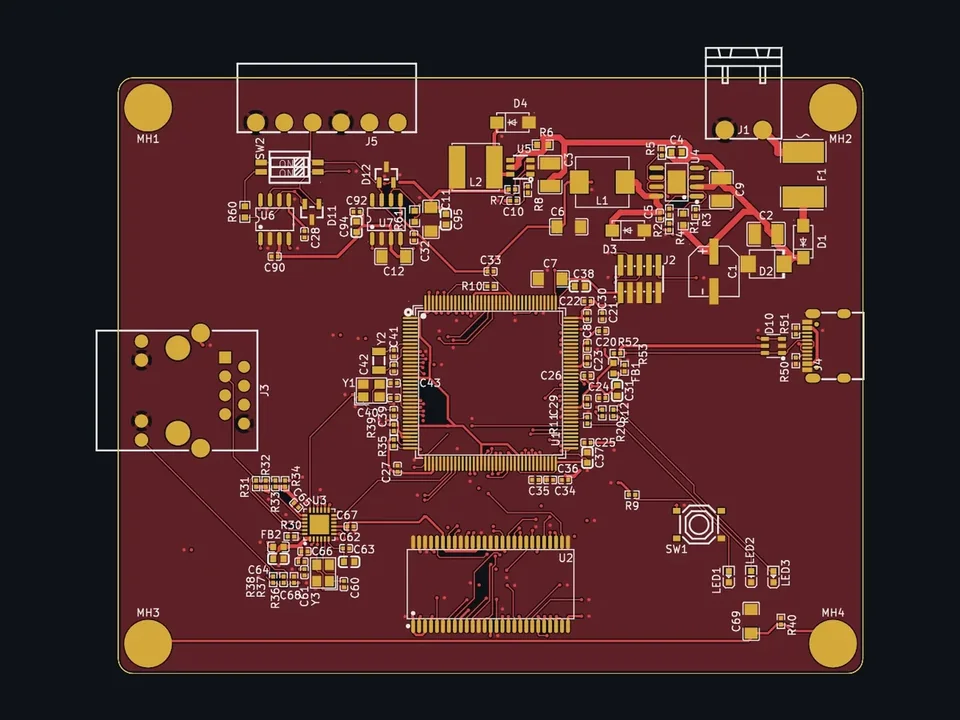
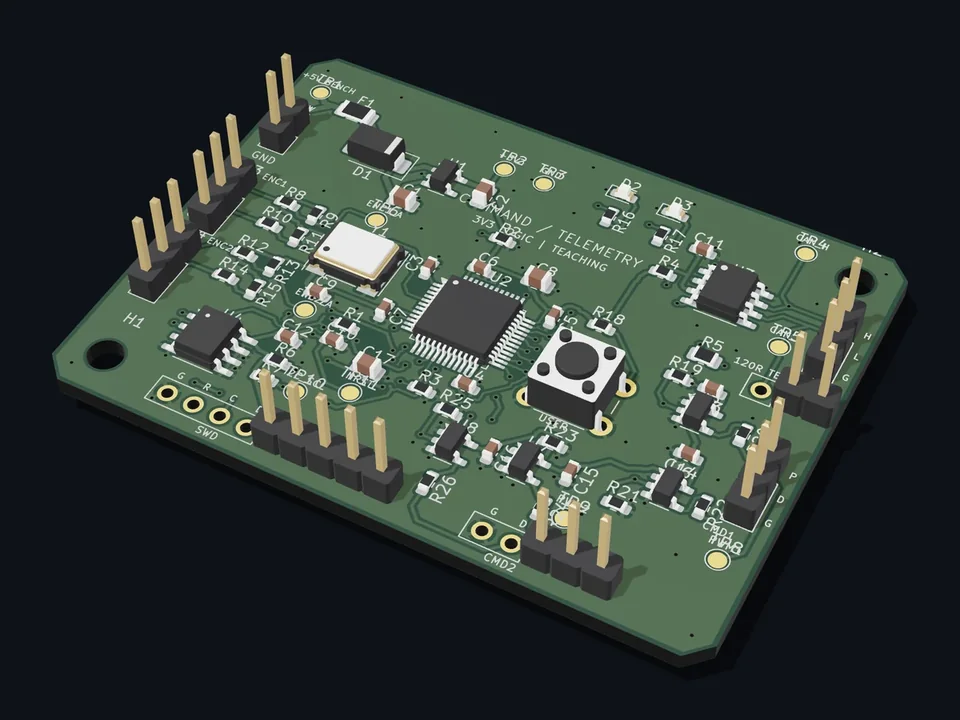
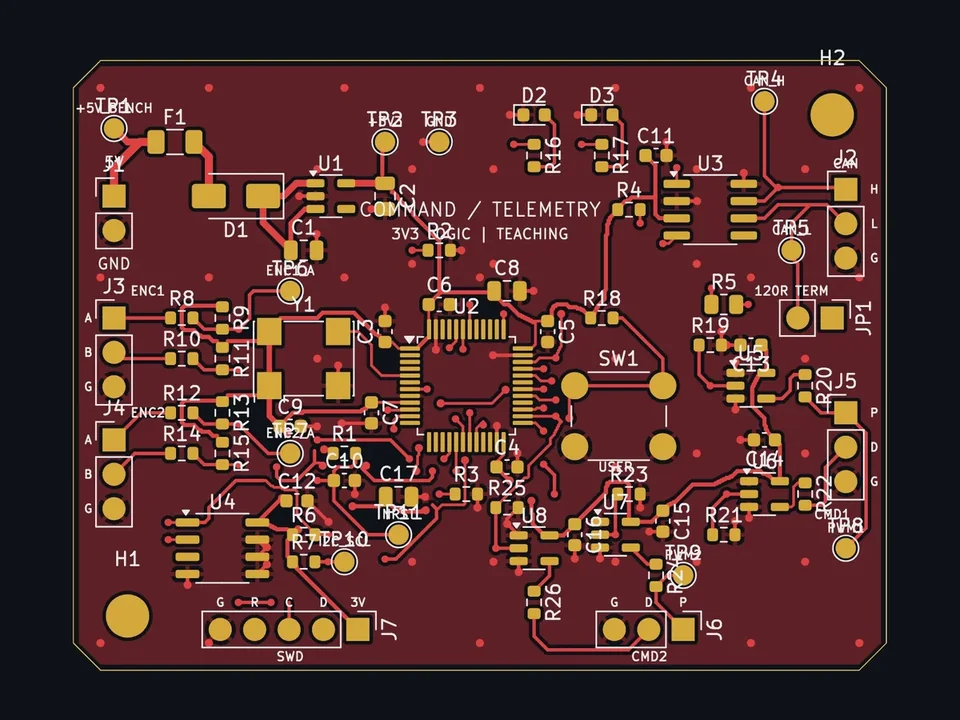
Design a robot peripheral control and telemetry PCB for a mobile or manipulation robot.
The board should accept a nominal 24 V DC input and provide protected, regulated power and low-voltage interfaces for sensors, encoders, actuators, and a central robot computer. This is a generic development board, not a safety-certified controller or high-power motor driver.
Read the full prompt (3,158 characters) ↓Hide the full prompt ↑
Include these functional blocks:
1. Power input and protection
- 24 V input through a two-position screw terminal
- Replaceable input fuse
- Reverse-polarity protection
- TVS diode for transient protection
- Power-status LED
- Test points for input voltage and ground
2. Regulated power
- 24 V to 5 V buck-converter stage
- 5 V to 3.3 V regulator
- Decoupling and bulk capacitance around each supply
- Separate headers exposing protected 24 V, 5 V, 3.3 V, and ground
- Power-good LEDs for the 5 V and 3.3 V rails
3. Controller
- STM32 microcontroller with a commonly available LQFP footprint
- SWD programming header
- Reset pushbutton
- Boot-configuration components
- External crystal if required
- Proper decoupling on every MCU supply pin
4. Robot communication
- One protected CAN bus interface with transceiver, switchable 120-ohm termination, and a four-pin connector
- One RS-485 interface with transceiver, termination and biasing components, and a four-pin connector
- One UART expansion header
- Clearly label communication connectors and test points
5. Sensor inputs
- Four digital sensor or limit-switch inputs
- Each input should support an external 5–24 V signal through protection and level conditioning
- Add input-status LEDs
- Two analog sensor inputs with filtering and overvoltage protection
- Two quadrature encoder connectors with A, B, index, power, and ground
6. Low-current outputs
- Four protected low-side MOSFET outputs for small relays, solenoids, lights, or fans
- Include gate resistors, pull-down resistors, flyback protection, and output-status LEDs
- Use separate connectors for each output
- Keep these outputs explicitly low-current; do not create a motor-power stage
7. Safety and service interfaces
- One externally wired emergency-stop status input that the MCU can monitor
- Do not claim that this input provides a certified safety function
- Add a watchdog/status LED
- Add labeled test points for the main power rails, CAN, RS-485, and key MCU signals
Organize the schematic into clearly labeled functional blocks. Use real, commonly available parts with footprints wherever possible. Add net labels and connector labels that make the signal flow easy to understand.
Keep the PCB practical for automated placement and routing:
- Two-layer board
- Approximately 100 mm by 80 mm
- Four mounting holes
- Power circuitry on one side
- MCU and communications in the center
- Field connectors around the board edges
- Keep high-current paths short and wide
- Keep switching power circuitry away from analog inputs and communication signals
- Include a ground plane
Generate a complete, editable schematic suitable for conversion into a PCB. Do not add Wi-Fi, Ethernet, high-power motor drivers, battery charging, or functional-safety circuitry.