Openrover Robotic Platform
by pol-valero
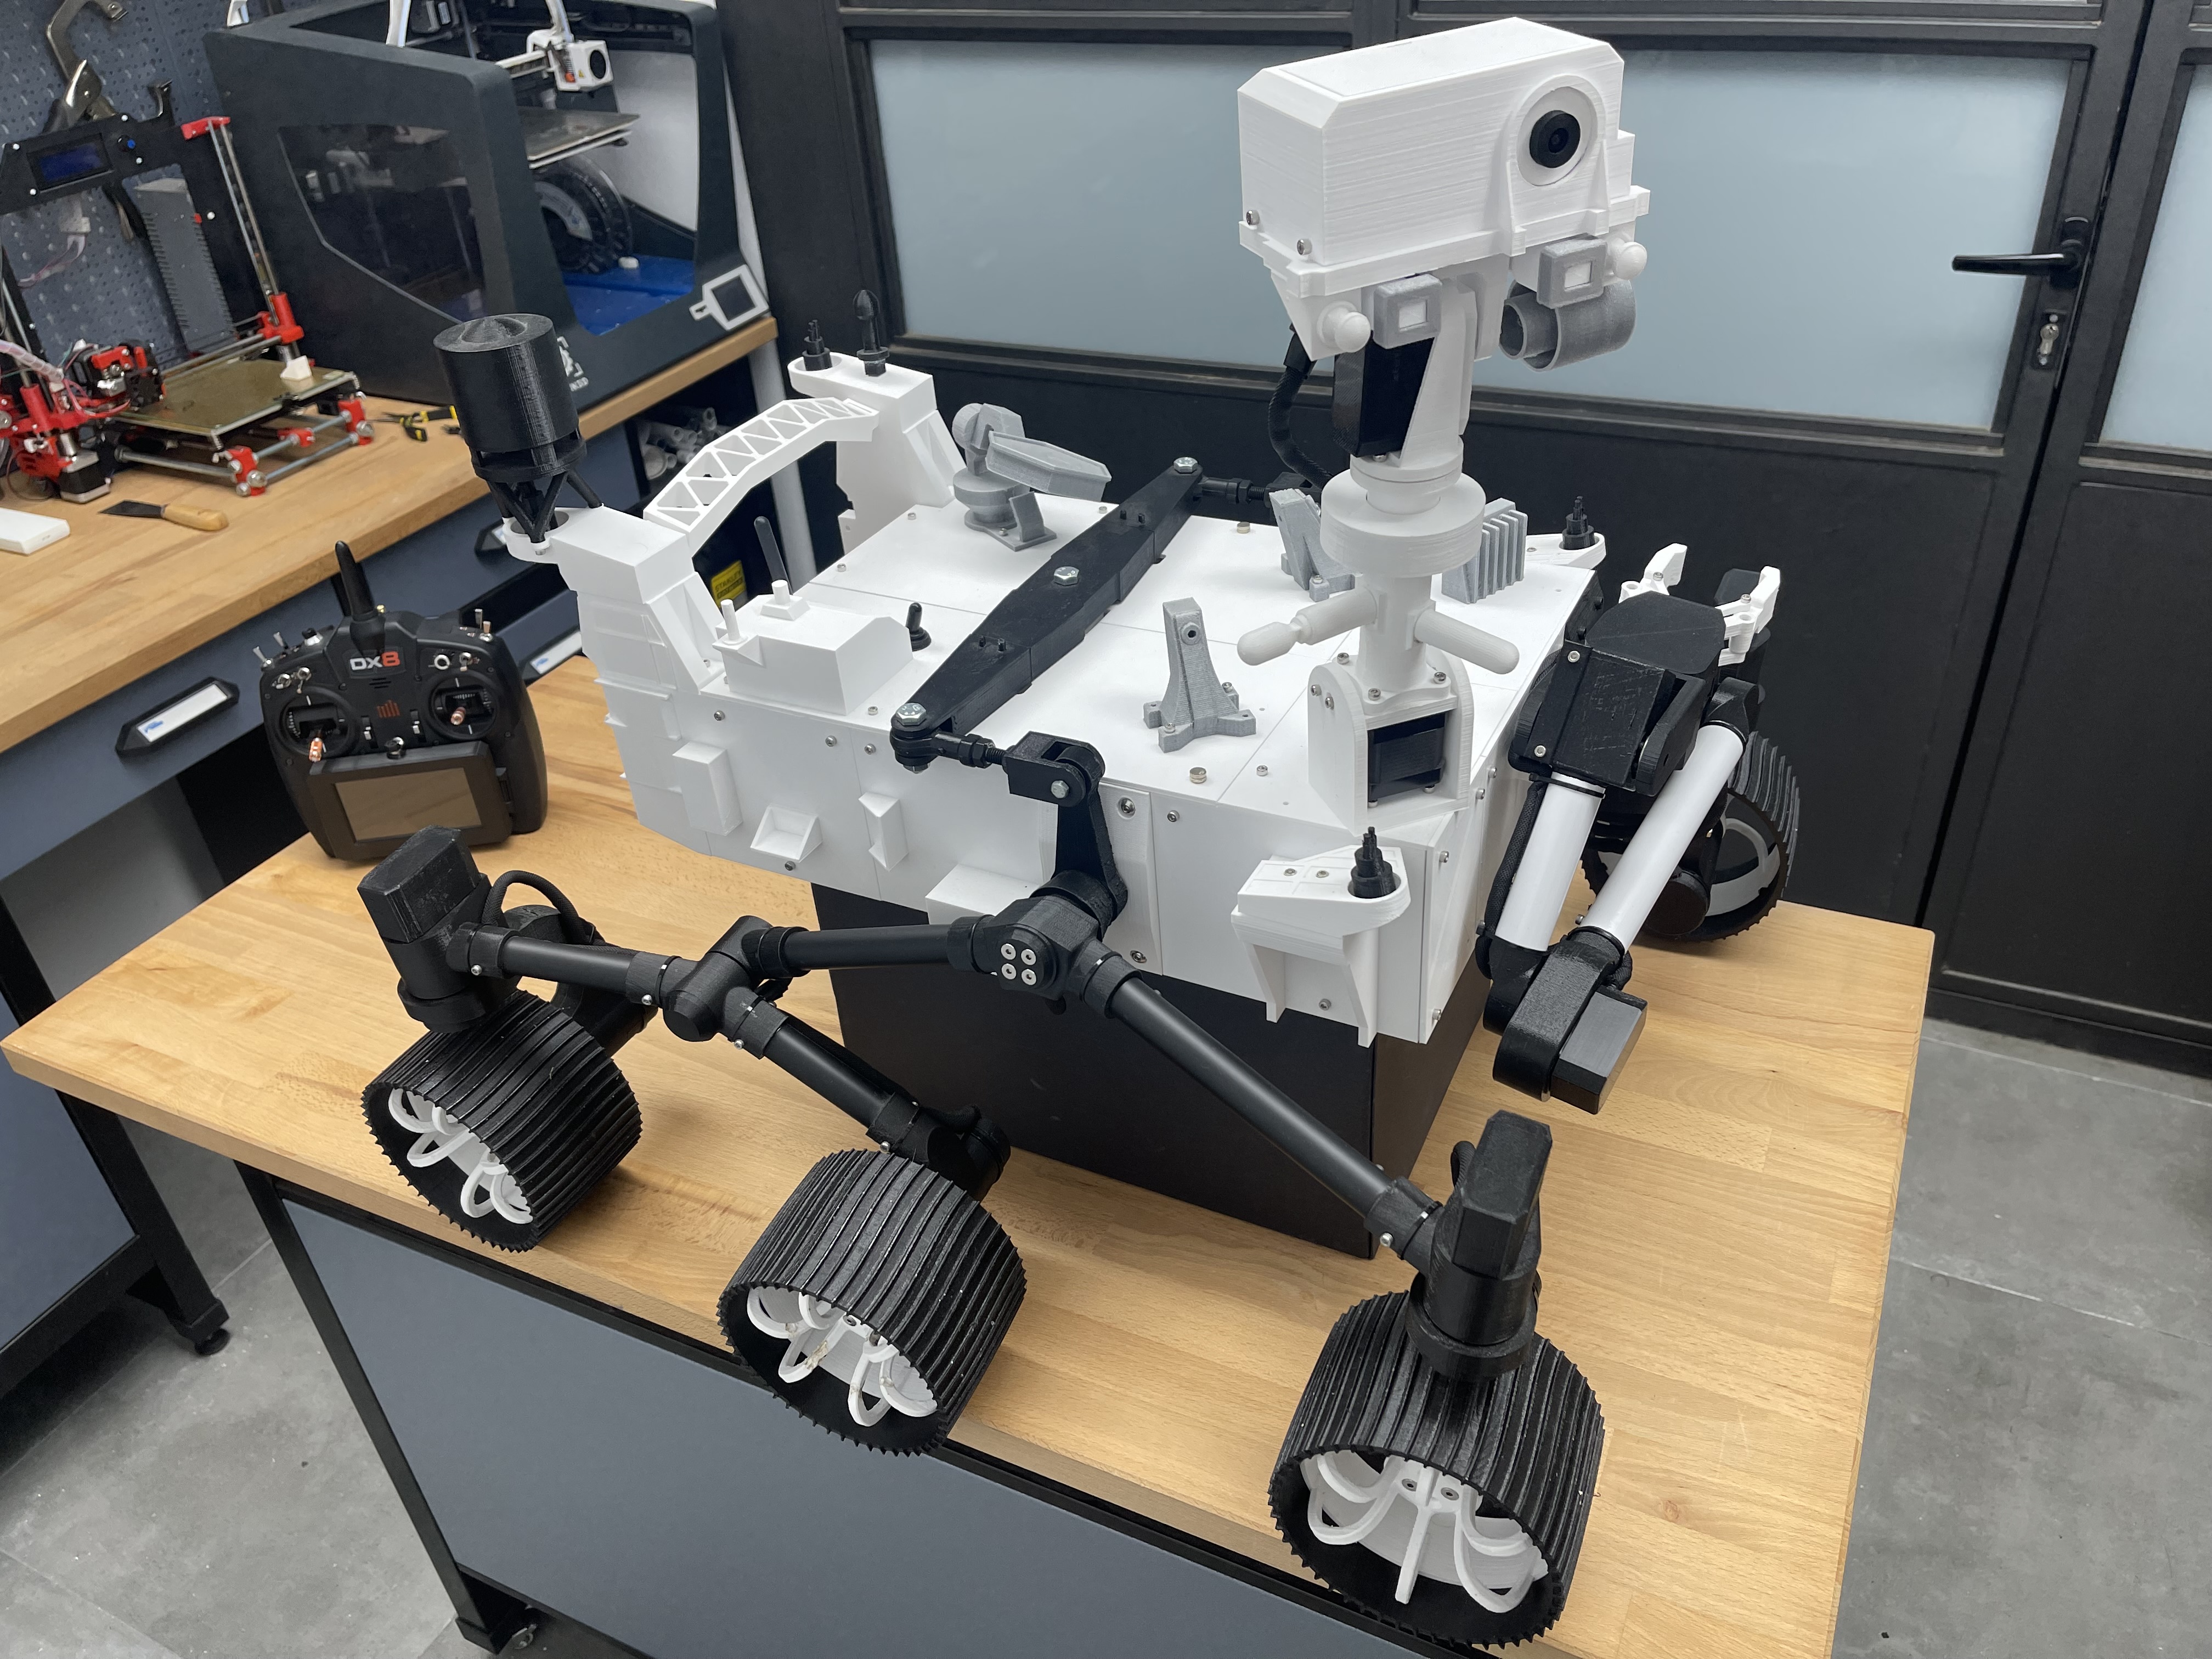
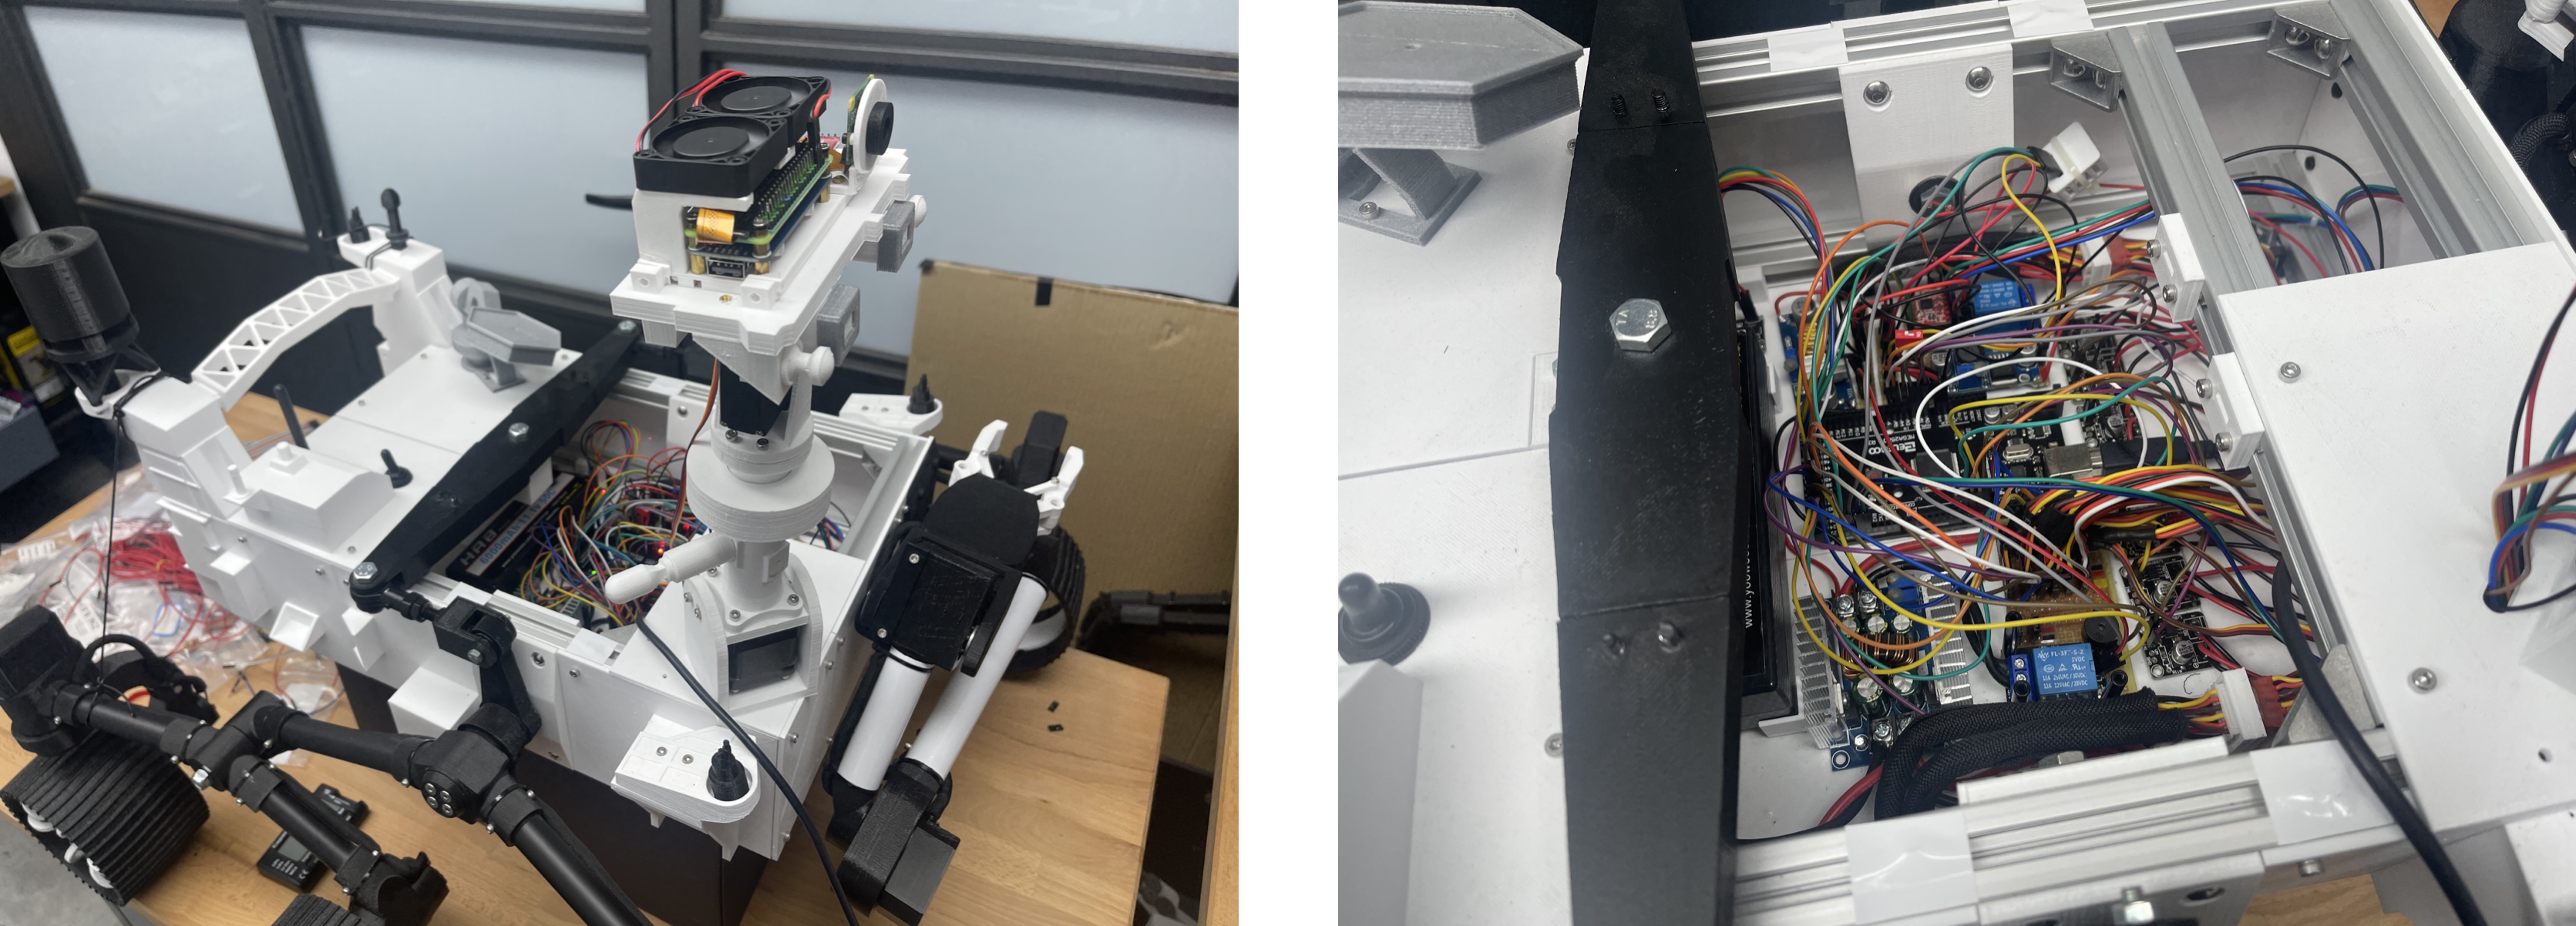
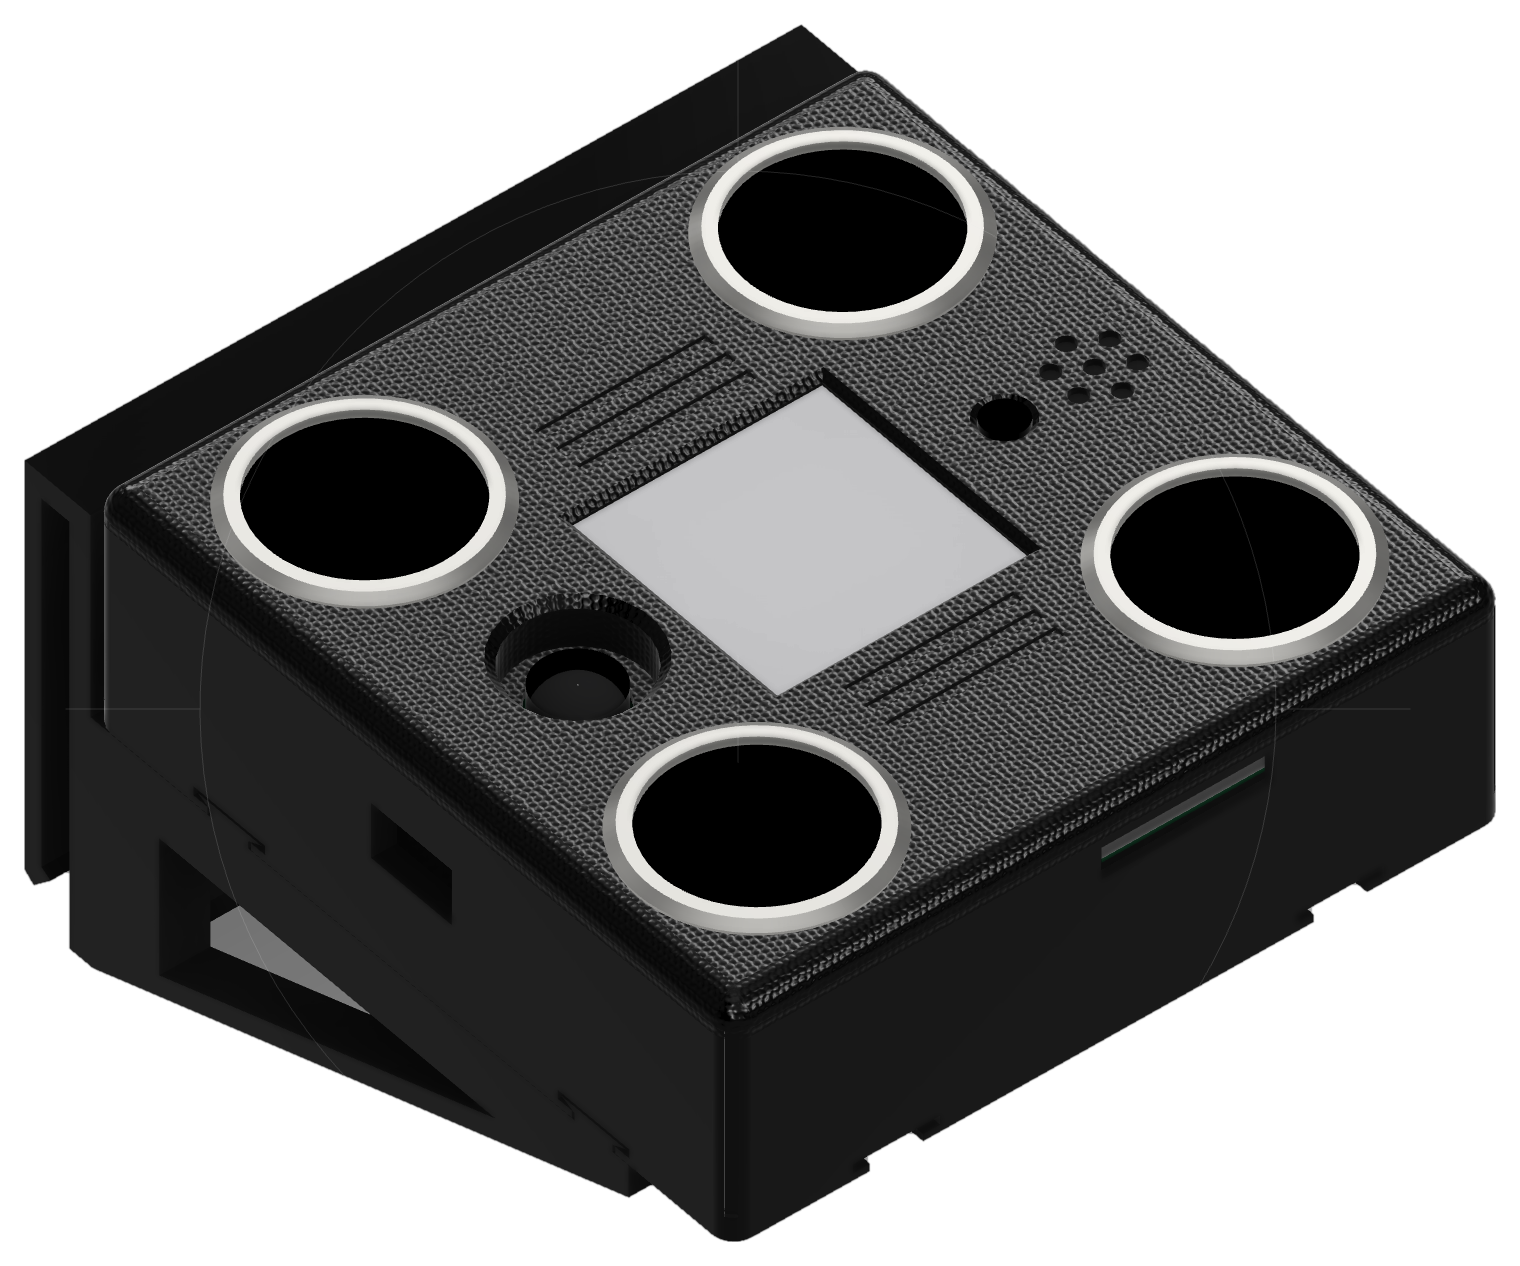
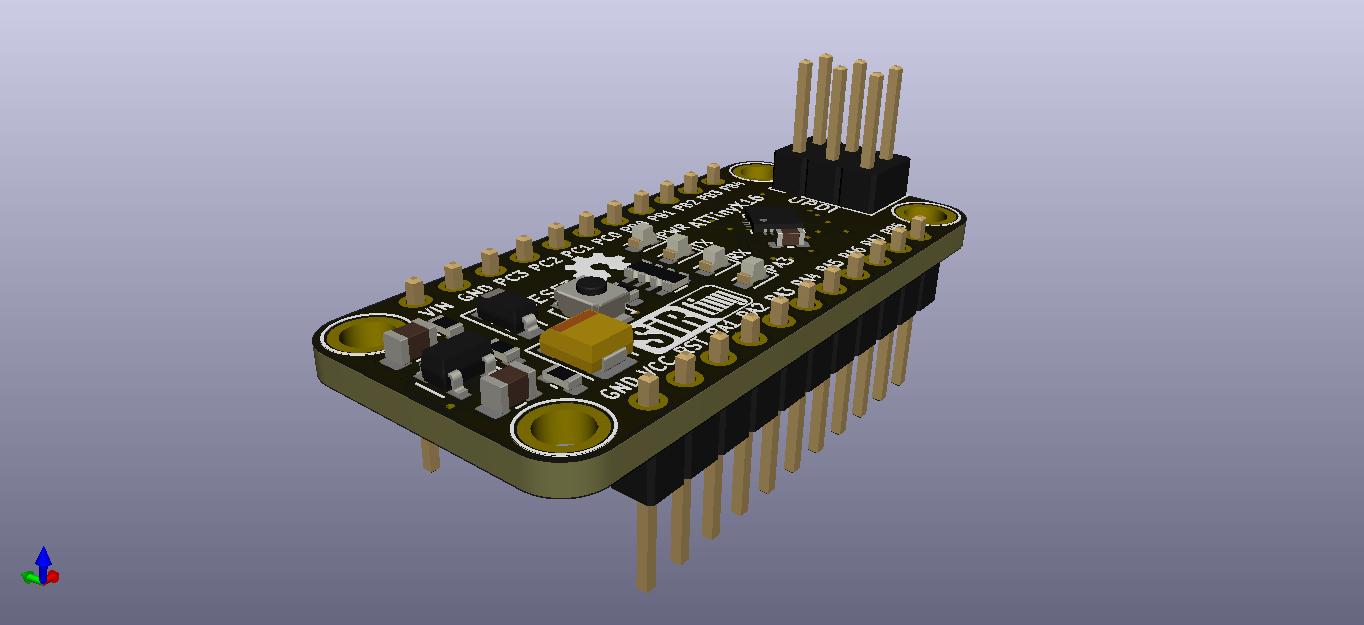
pol-valero maintains Openrover Robotic Platform, an open hardware microcontroller board whose source files are public on GitHub. In the maintainer's words: “3D-printed Mars Rover robot inspired by NASA’s Perseverance rover. Built using Raspberry Pi, ESP32, and Arduino boards. It includes a web dashboard and a remote control with a touchscreen for monitoring and control.”
It has 29 stars and 5 forks on GitHub, with the last commit 9 months ago.
What’s in the repository
- Schematic and board source files published by the author
- Full revision history, so you can see how the board changed between versions
Licence and reuse
Released under MIT, one of the permissive licenses. You can fork the design, change it, manufacture it and sell the result, provided you keep the original copyright and license notice with the files.
Opening it in ProtoFlow
The repository does not clearly state which EDA tool produced the files — check the repository contents before planning an import.
- 01 Select “Edit in ProtoFlow” for opening options. Download the source and open supported KiCad files in the app. Other EDA formats may need conversion.
- 02 Work in the imported local copy: rename nets, swap parts against live distributor stock, re-route, or strip it back to the sub-circuit you actually need.
- 03 Keep the original licence and credit pol-valero if you publish or sell what you build from it.
This page indexes a public repository. The design, the files and the copyright belong to pol-valero; ProtoFlow does not host, mirror or verify them. Details are read from GitHub and refreshed periodically — check the repository for the current state of the project.