MarsRoverHardware
by uwrobotics
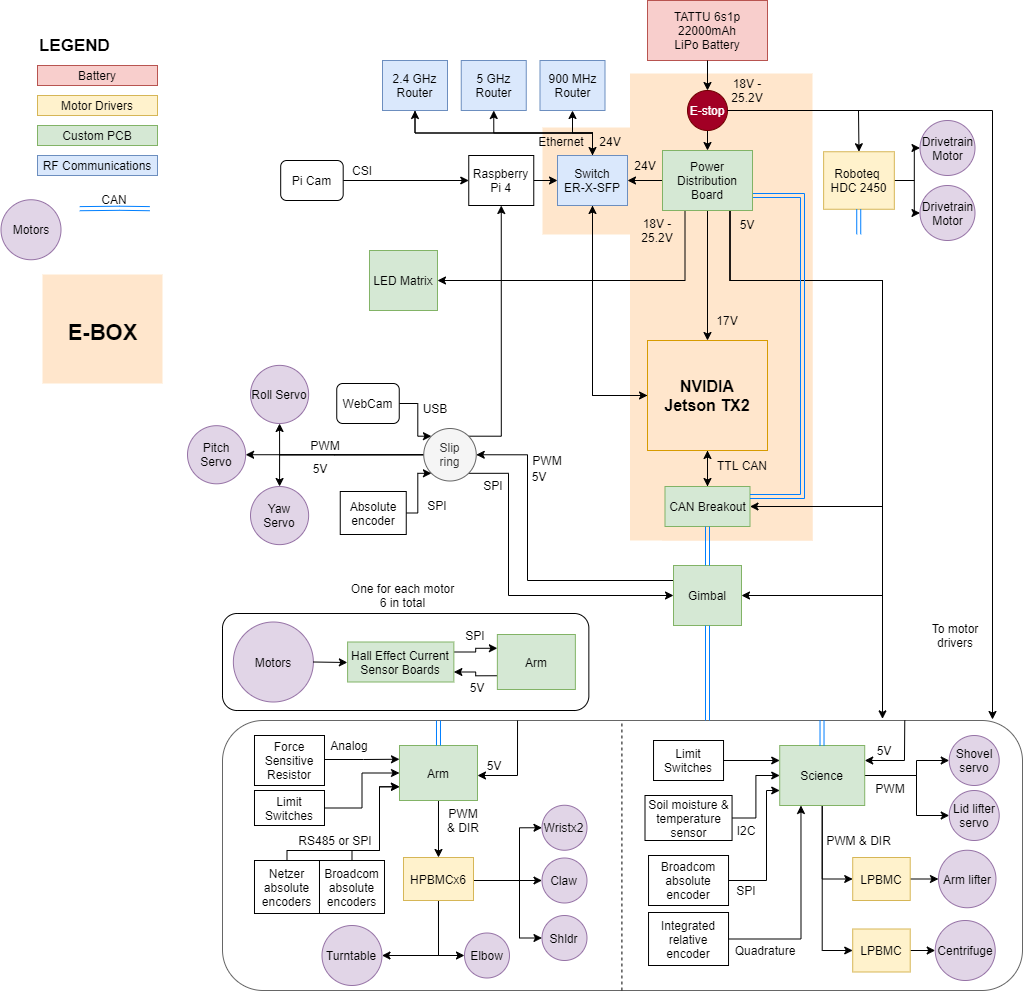
uwrobotics maintains MarsRoverHardware, an open hardware motor control board whose Altium source files are public on GitHub. The author describes it as: “PCB designs for the University of Waterloo Robotics Team.”
100 people have starred it and 24 have forked it, with the last commit about a year ago.
What’s in the repository
- Altium project source files
- A project site with further documentation
- Full revision history, so you can see how the board changed between versions
Licence and reuse
Released under CC-BY-SA-4.0, a copyleft license. You are free to fork and modify the design, but anything you distribute that is derived from it has to be published under the same terms — worth checking before it goes into a closed product.
Opening it in ProtoFlow
The design was drawn in Altium Designer. Altium projects need converting before they open in KiCad-compatible tools, so expect to check footprints and layer mapping after any import.
- 01 Select “Edit in ProtoFlow” for opening options. Download the source and open supported KiCad files in the app. Other EDA formats may need conversion.
- 02 Work in the imported local copy: rename nets, swap parts against live distributor stock, re-route, or strip it back to the sub-circuit you actually need.
- 03 Keep the original licence and credit uwrobotics if you publish or sell what you build from it.
This page indexes a public repository. The design, the files and the copyright belong to uwrobotics; ProtoFlow does not host, mirror or verify them. Details are read from GitHub and refreshed periodically — check the repository for the current state of the project.